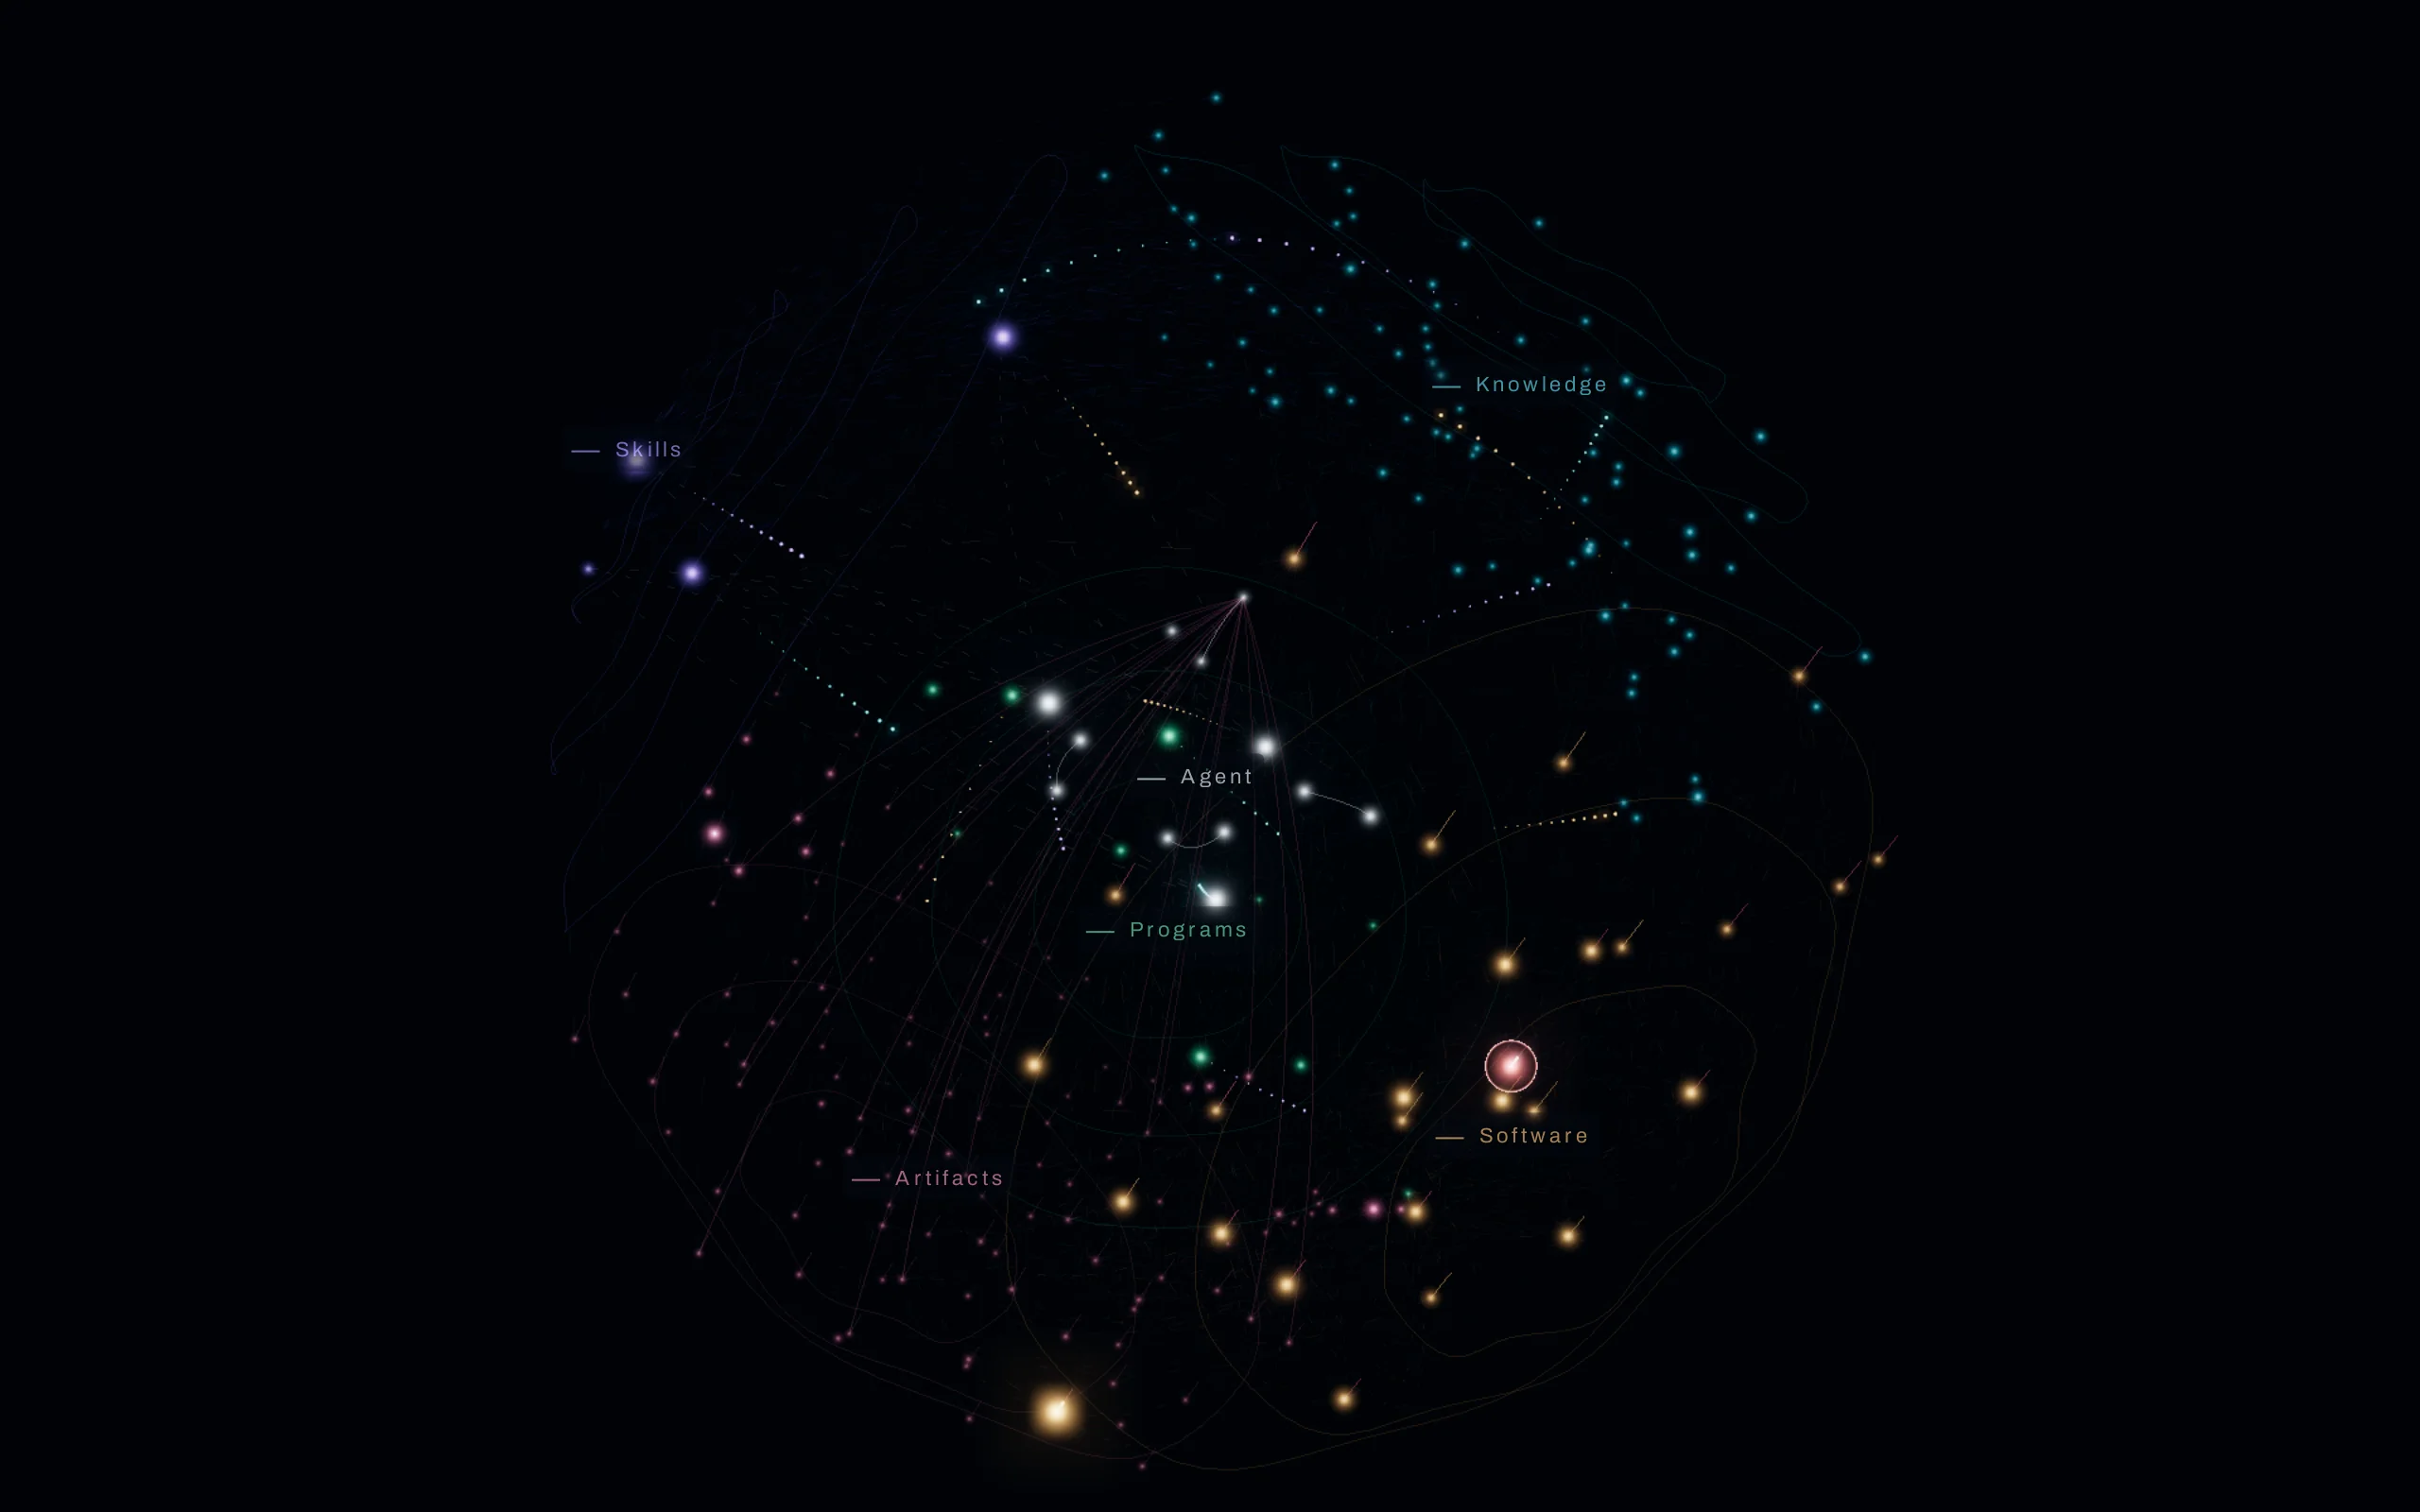
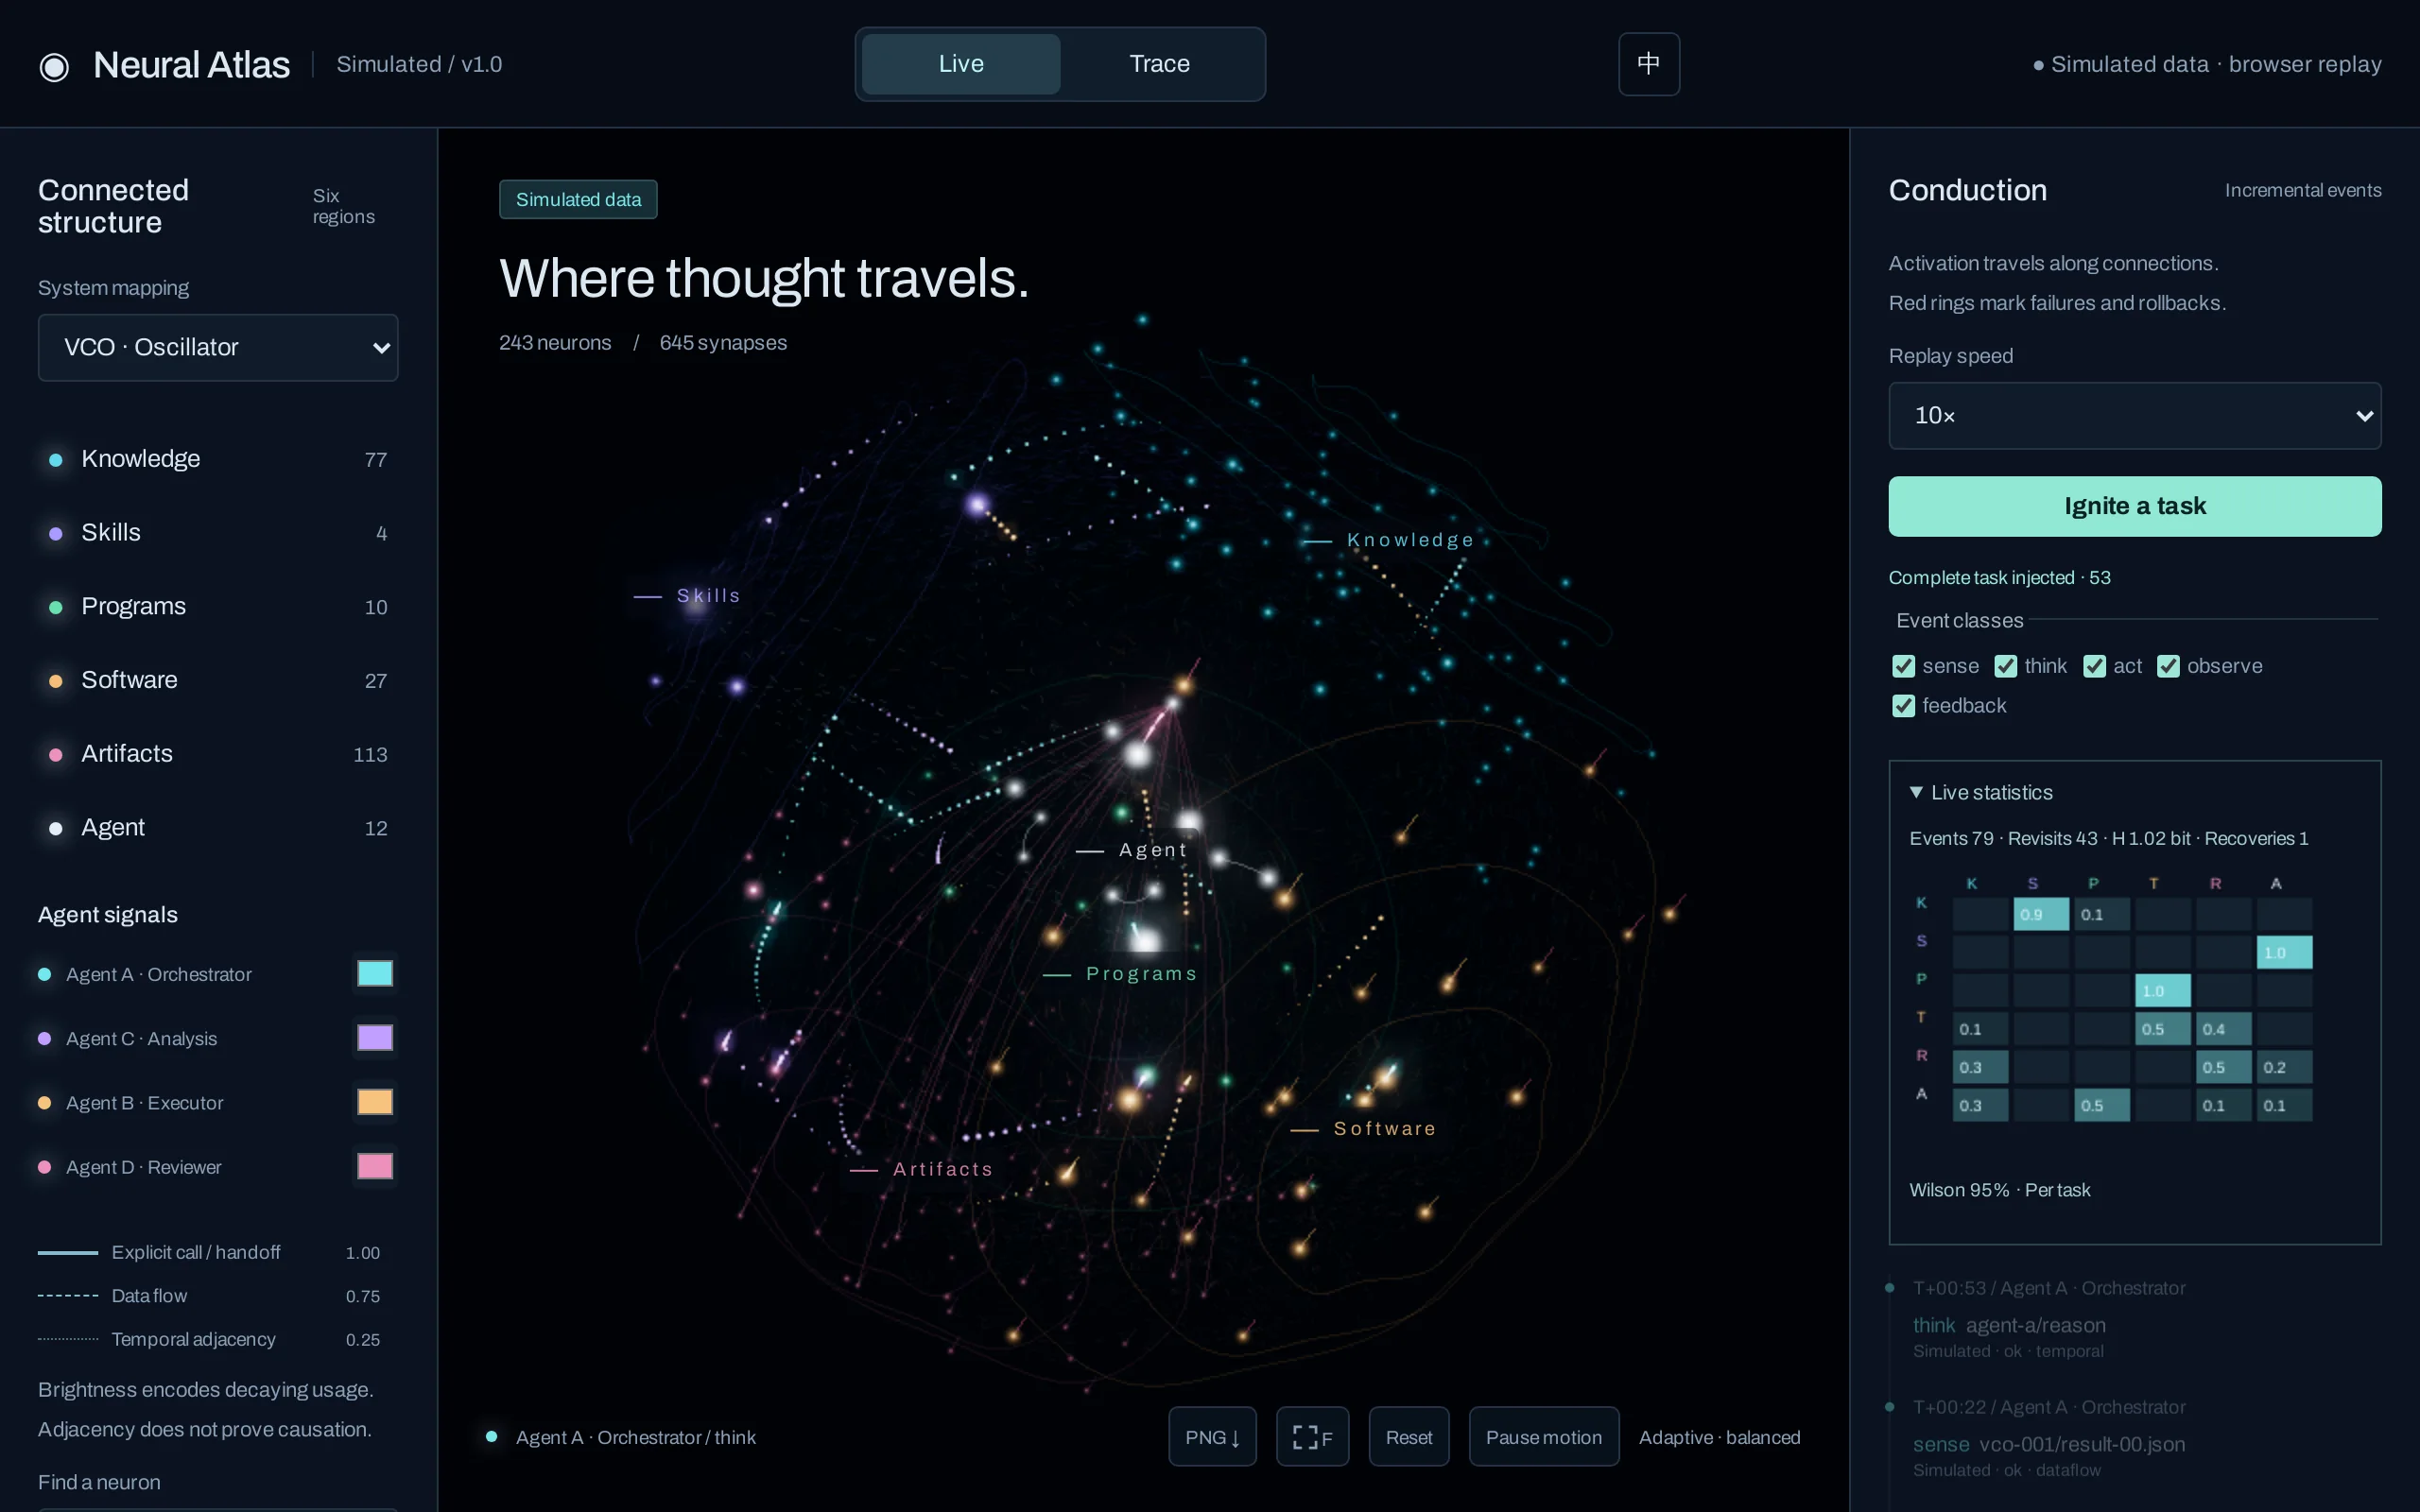
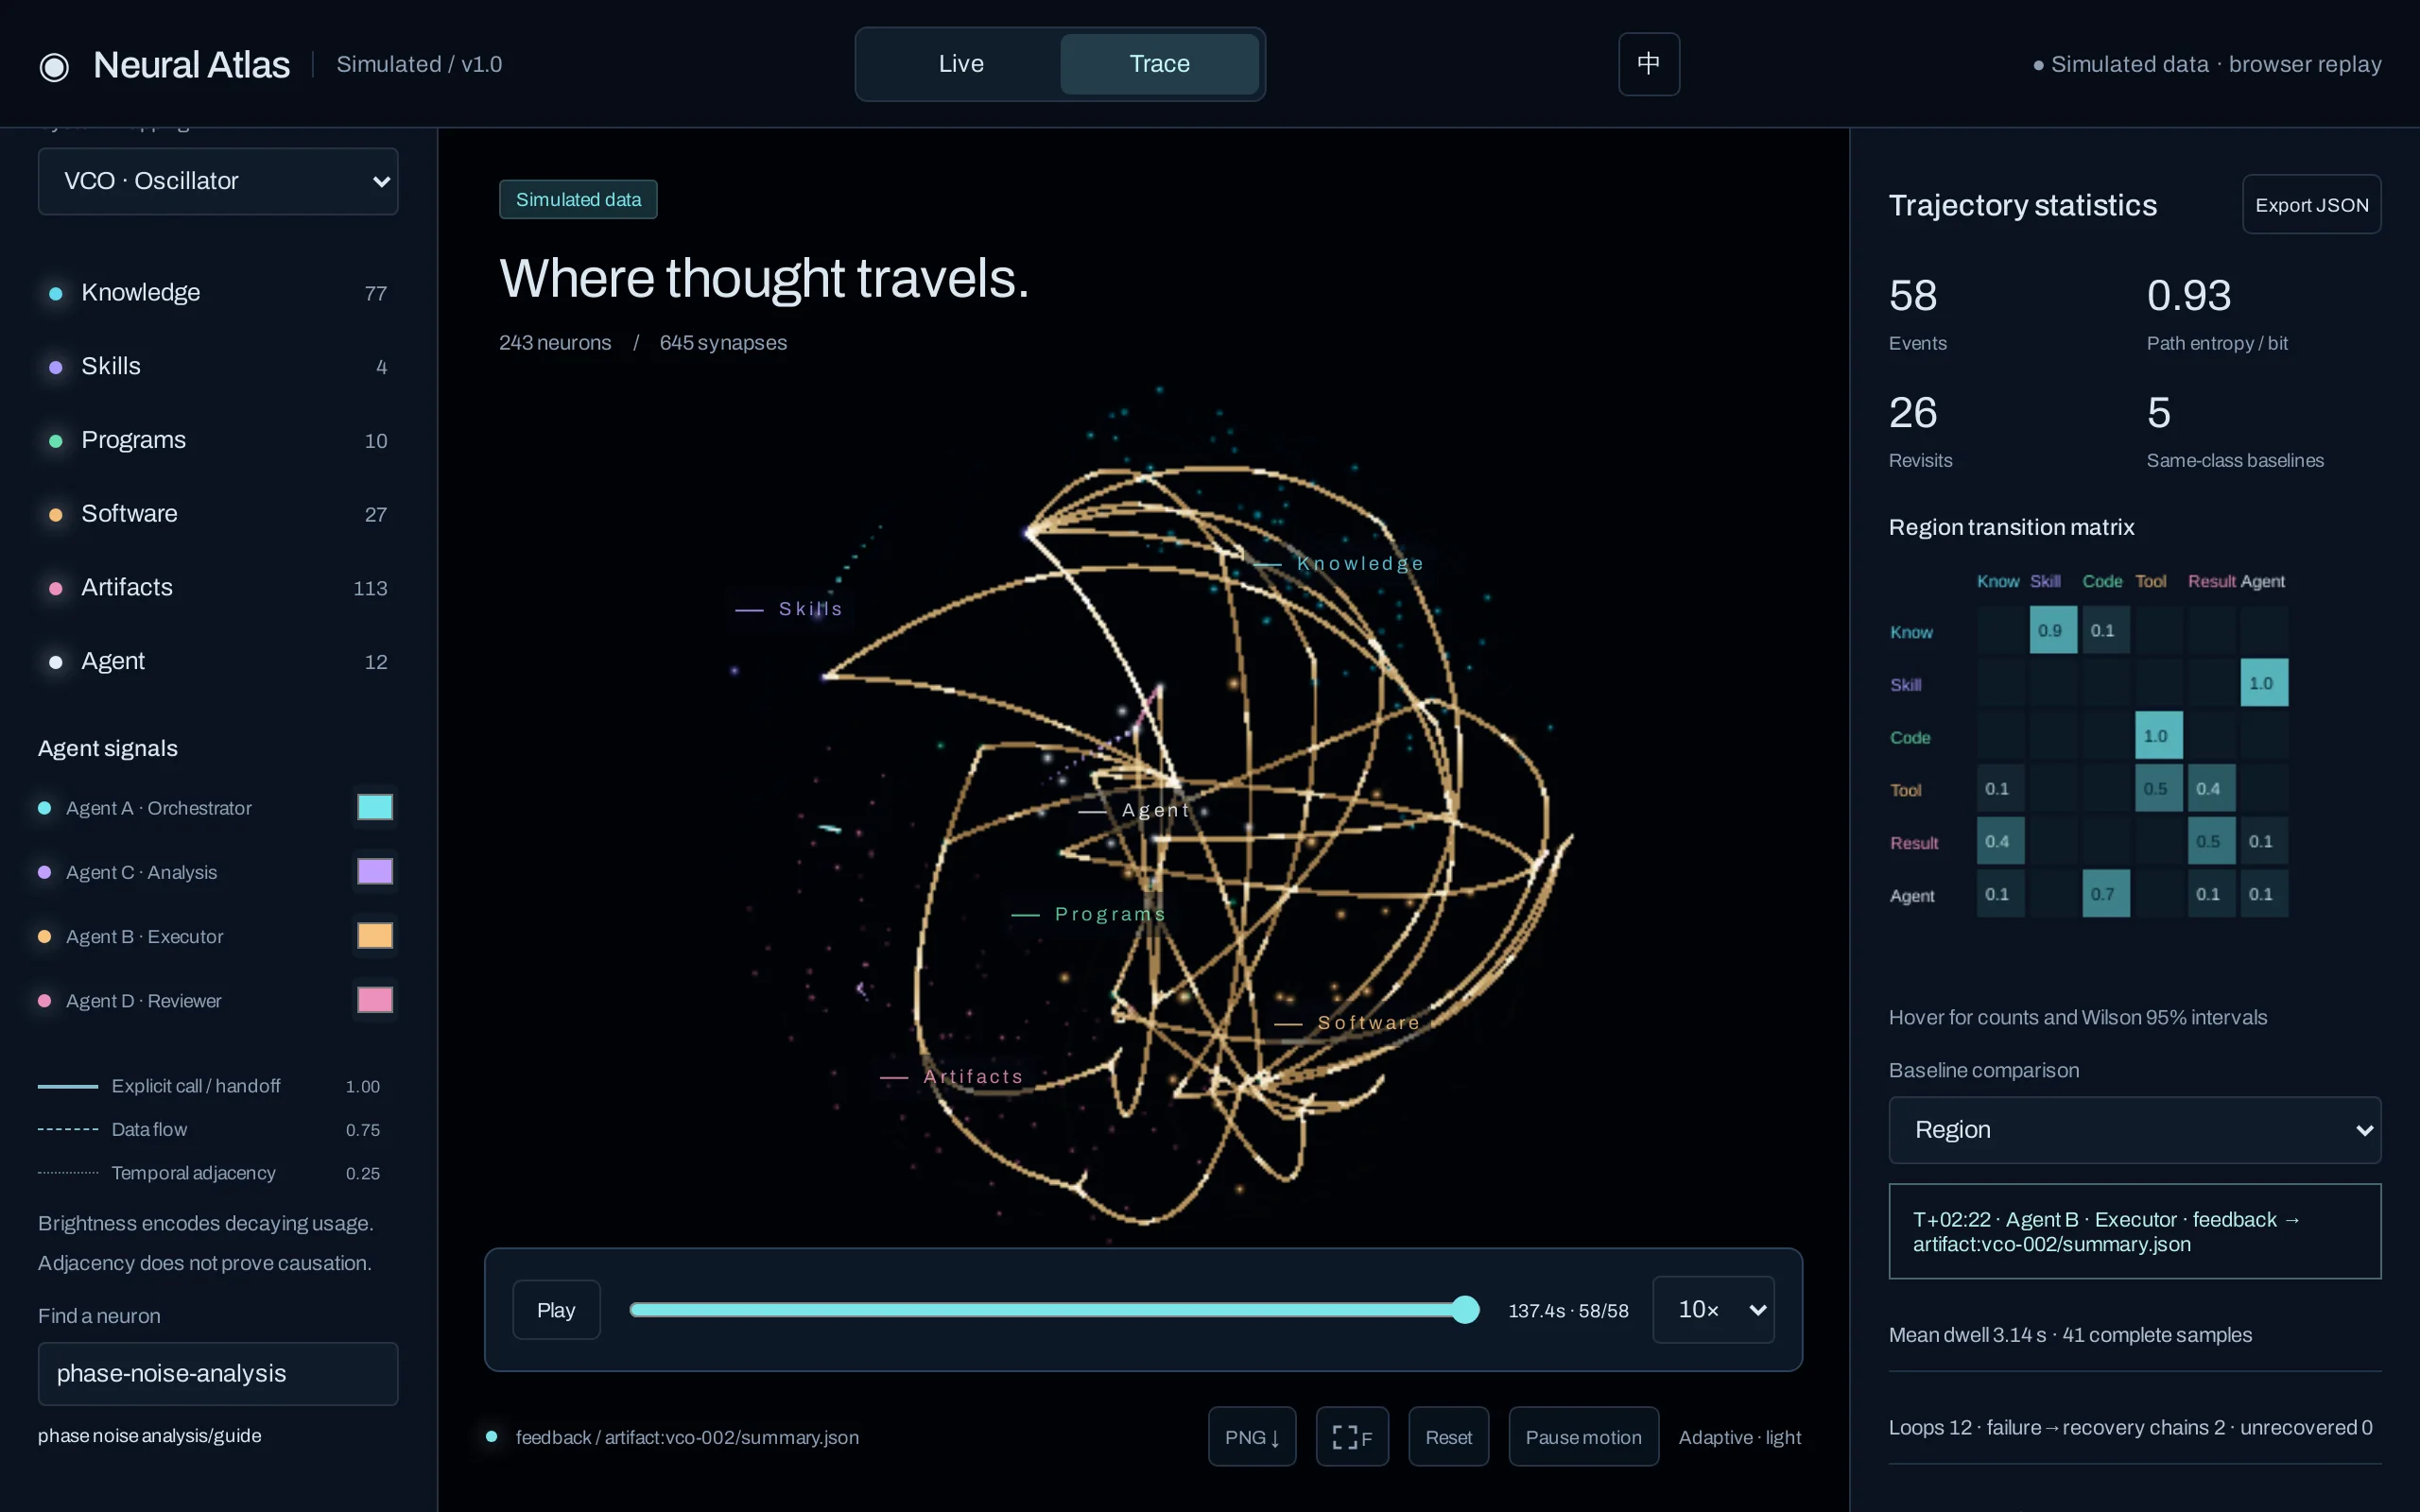
一次设计,穿过知识、技能、程序和专业软件。Neural Atlas 把这些已有的活动连成一张脑图:看它怎样前进,在哪里回退,又如何找到出路。A task moves through knowledge, skills, programs and specialist software. Neural Atlas connects those activities so you can see the next step, the detour, and the recovery.
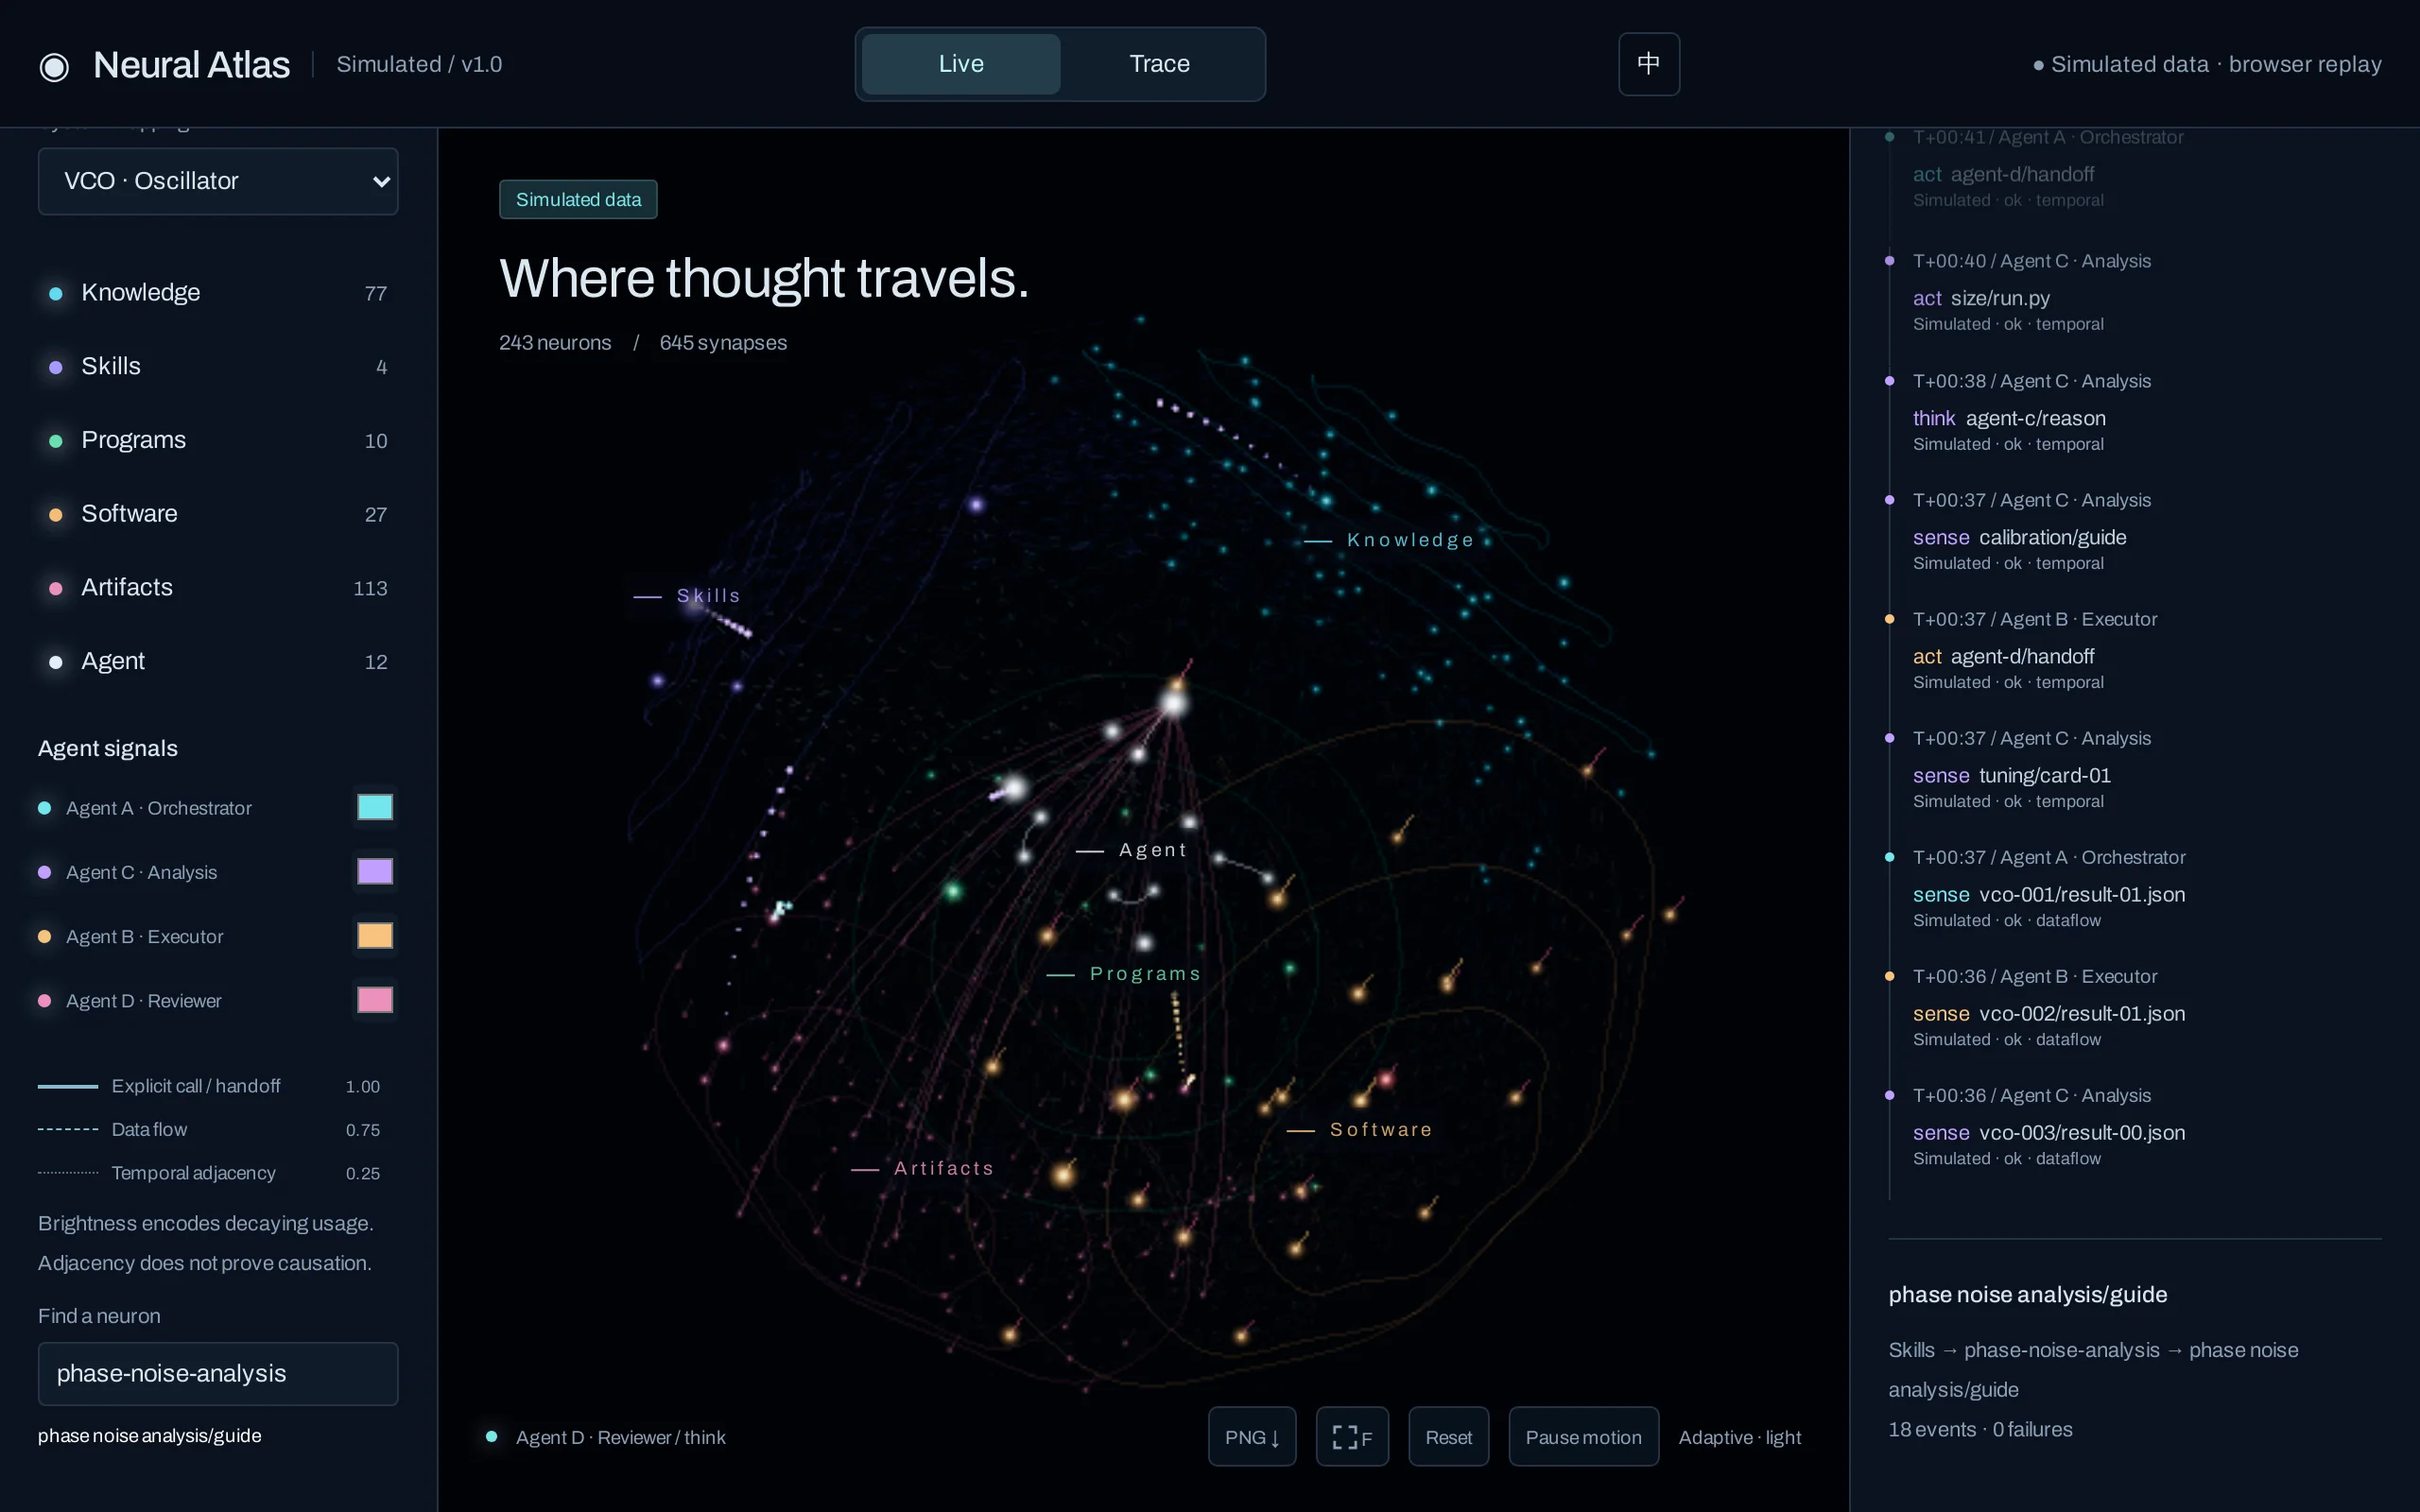
只读、增量读取智能体已经写下的日志。无需埋点,不阻塞任务;三维渲染交给访问者的浏览器。Read the logs agents already write, incrementally and read-only. No instrumentation and no blocking. The visitor’s browser renders the atlas.
既有测试参考:空闲 CPU 0.17%,RSS 约 45 MB;每秒 5 个事件时 CPU 约 0.5%。这是观察器测量值,不是本网页的性能承诺。Prior observer measurements: 0.17% idle CPU, about 45 MB RSS; about 0.5% CPU at 5 events/s. These measure the observer, not this page.
换个领域,结构依然成立。New domain. Same structure.
知识库 + 技能 + 用户程序 + 专业软件:具备这四层的系统,用一份映射配置即可接入。区域与事件语义保持统一。Knowledge + skills + user programs + specialist software: map a system with these four parts using one pack configuration. Regions and event semantics stay consistent.
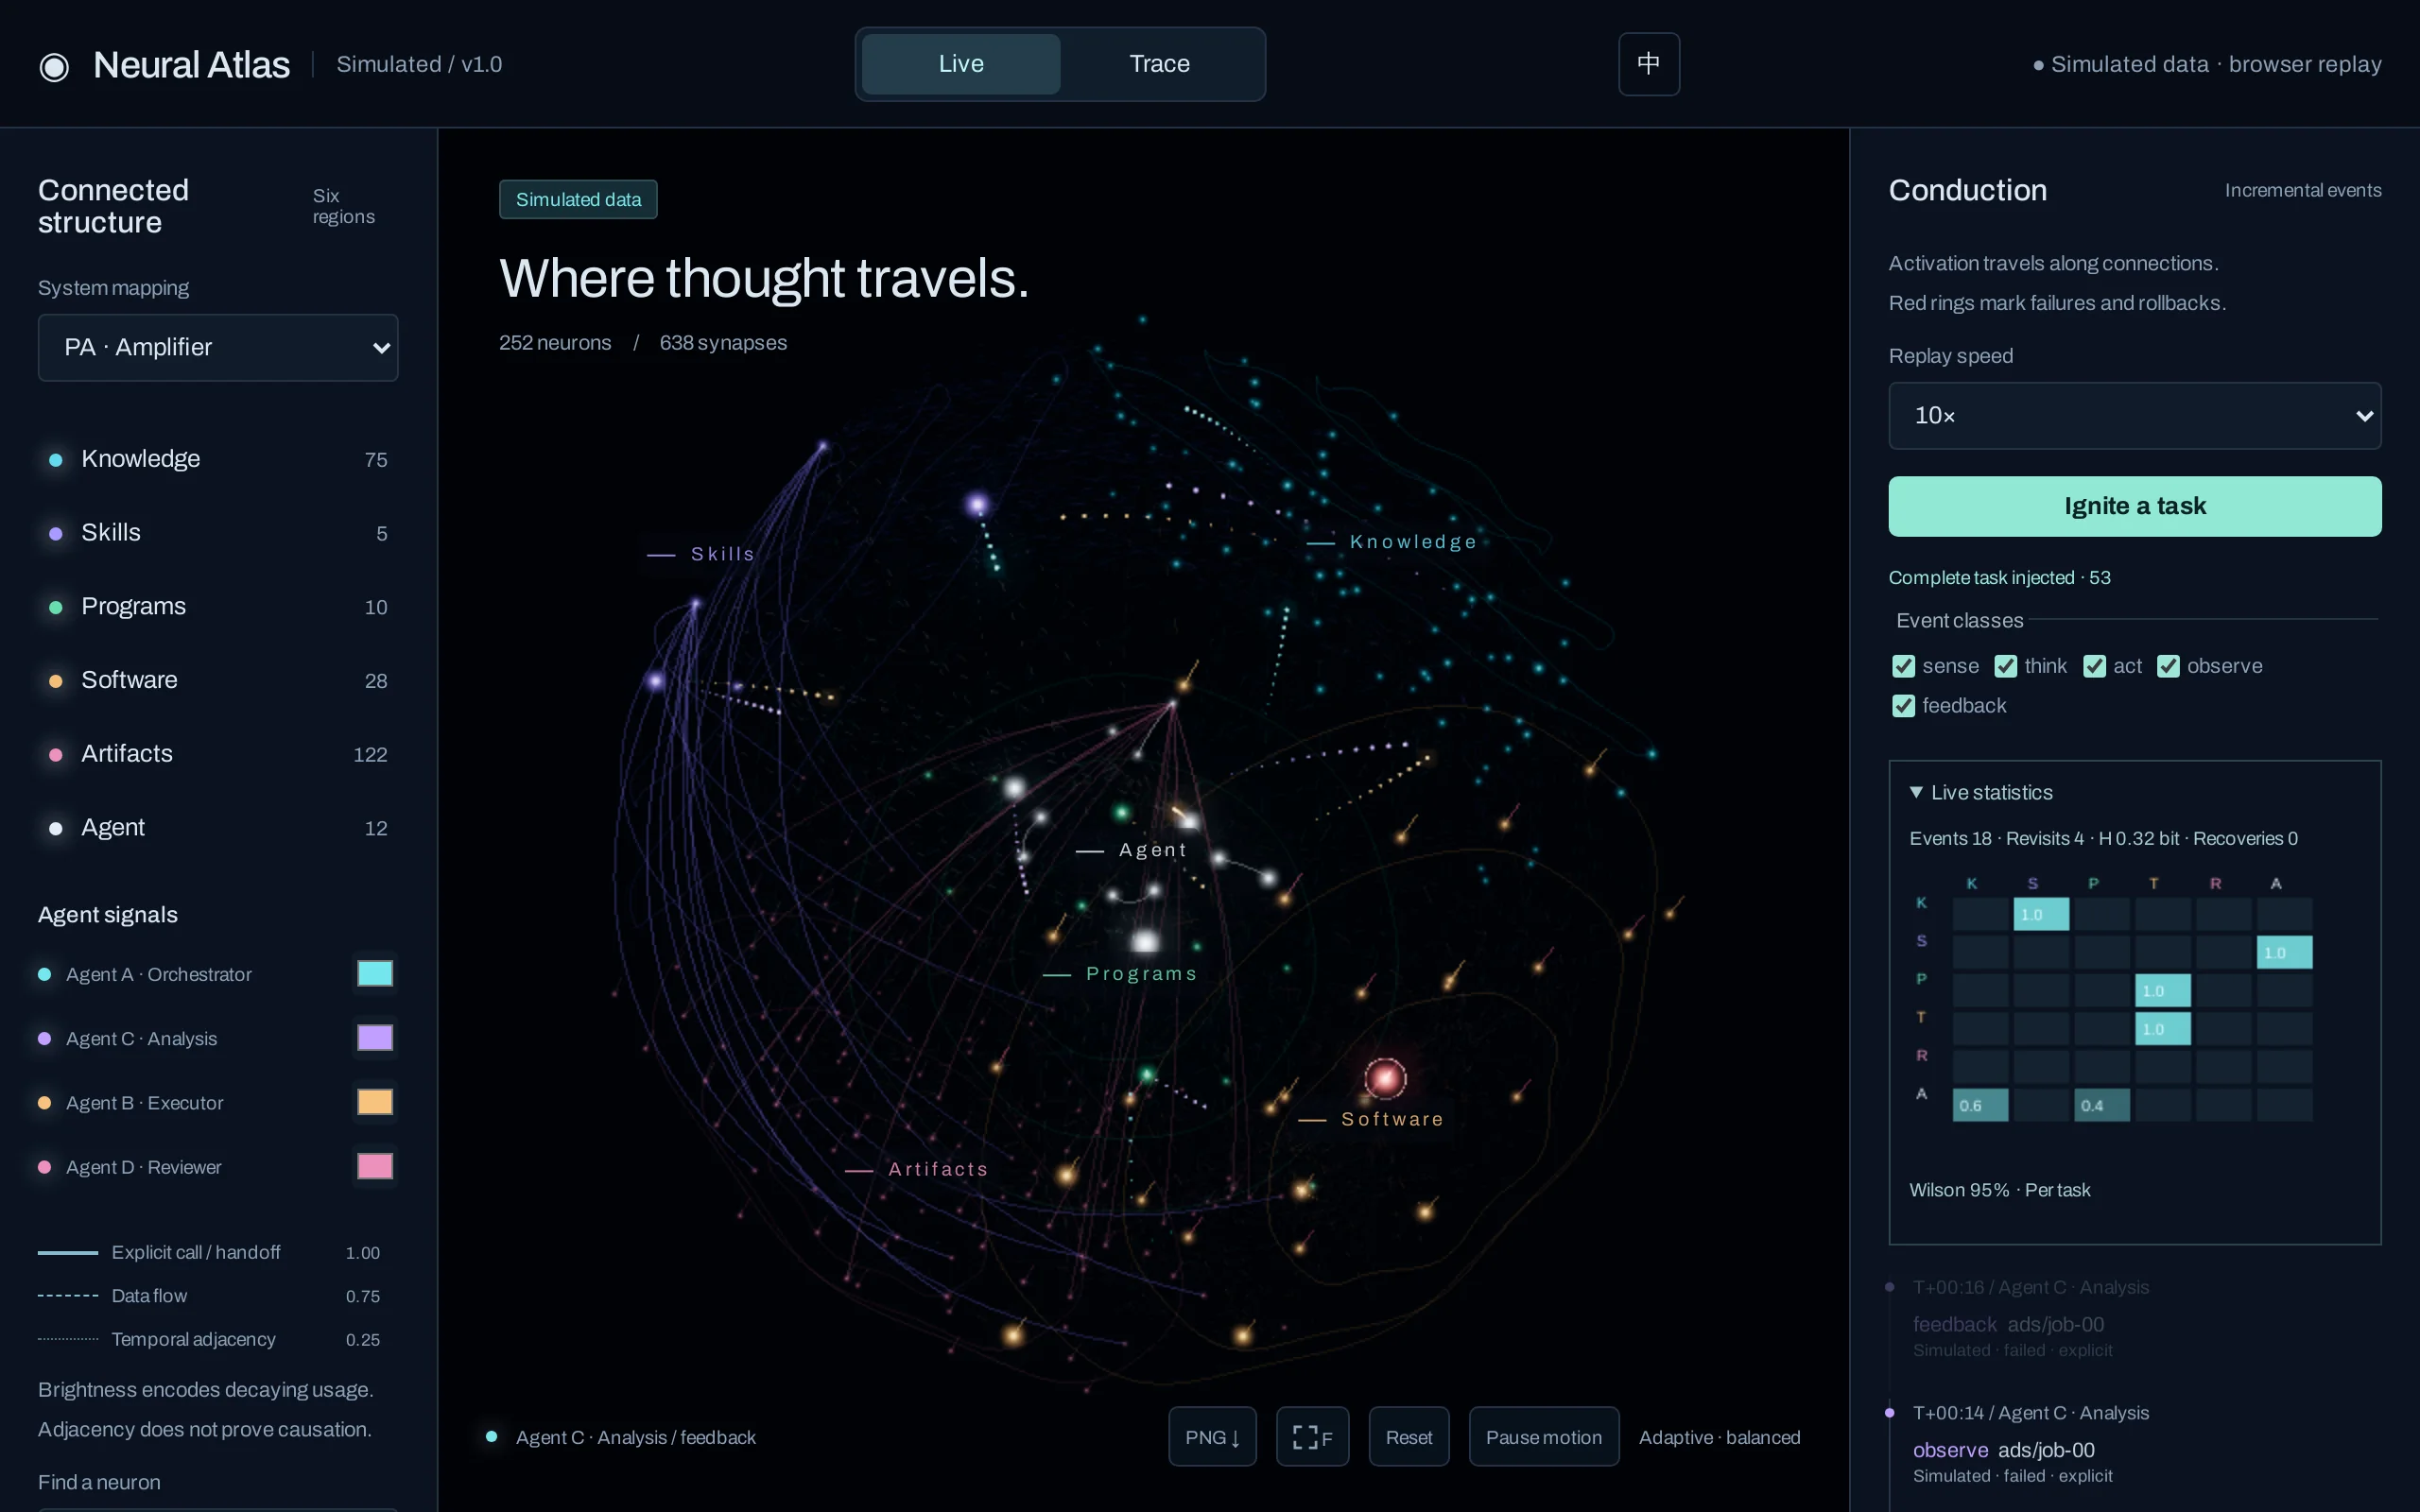
振荡器、功放与数据分析共用同一套图谱。下方可直接切换。Oscillator design, amplifier design and data analysis share the same atlas. Switch between them below.
突触强度是随时间衰减的使用痕迹;抑制标记失败与回退。时间相近本身不能证明因果。Synaptic strength is a decaying usage trace. Inhibition marks failure or rollback. Temporal proximity alone does not establish causation.
━━ 显式调用Explicit┄┄ 数据流Data flow···· 时间邻接Temporal
把一次绕路,放回全局。Put a detour in context.
从 Live 看交错活动,在 Trace 读完整任务。Markov 转移矩阵与 Wilson 95% 区间、路径熵、重访与回路、失败恢复链和临界路径,帮助解释一次任务。Watch interleaved activity in Live; inspect a complete task in Trace. Markov transitions and Wilson 95% intervals, path entropy, revisits, loops, failure→recovery chains and critical paths help explain the journey.
按区域或簇,对照同类成功任务的 z-score。样本不足或方差为零时不报告 z 值;统计是描述性的。Compare region or cluster transitions to same-class successful tasks with z-scores. No z-score is reported for undersized or zero-variance baselines. Statistics are descriptive.
VCO
相噪 / Phase noise
结构选型 / Architecture
尺寸与扫描 / Sizing & sweep
Spectre · EMX
PA
负载牵引 / Load-pull
负载线与匹配 / Load line & matching
扫描与提取 / Sweep & extraction
ADS · Spectre
Data
数据与方法 / Data & methods
清洗与建模 / Cleaning & modeling
变换与拟合 / Transform & fit
Python · DuckDB
任务怎样穿过脑图How a task travels through the brain
一次前进, 也包括一次回头。Progress includes the way back.
滚动页面,沿证据走完一次任务。Scroll to follow the evidence through a task.
1
提出规格Set the specification
把目标分解为可检查的约束,形成任务。Turn a goal into checkable constraints.
2
查阅知识Retrieve knowledge
找到已有知识卡,为下一步提供依据。Use existing knowledge cards to ground the next step.
3
选择技能Select a skill
选定设计方法,给出可执行的策略。Choose a method and an executable strategy.
4
运行程序Run a program
尺寸估算、参数扫描与结果处理形成程序调用。Sizing, sweeps and result processing become program calls.
5
调用专业软件Call specialist software
任务进入仿真或分析工具。此处仅回放合成事件。The task reaches a simulator or analysis tool. Here, all events are synthetic.
6
读回结果Read the result
结果成为可追溯的数据流,连接调用与判断。Results connect the tool call to the next decision through data flow.
7
诊断偏差Diagnose the deviation
检查失败和指标偏离,判断是否需要重试。Inspect failure and target deviations to decide on a retry.
8
形成反射弧Close the reflex arc
稳定性失败回到匹配技能;效率偏低回到负载线,再次验证。A stability failure returns to matching; low efficiency returns to the load line. Then test again.
交互实验台 · 全部为模拟数据Interactive bench · All data is simulated
下一次传导, 由你点燃。Start the next cascade.
切换系统,注入完整任务。悬停看突触邻域,点击区域聚焦;在 Trace 中拖动时间轴,读回每一步。Switch systems and inject a complete task. Hover to see neighbouring synapses, isolate a region, or scrub through a trajectory in Trace.
Live 默认 10× · Trace 默认到末尾 · F 沉浸模式 · PNG 本地截图 · JSON 统计导出Live starts at 10× · Trace starts at the end · F immersive mode · Local PNG capture · JSON statistics export
Local by design
公开的是结构。 留在本地的是数据。The structure is public. Your data stays local.
本页与应用中的事件、任务和图像全部来自固定种子的模拟数据,不包含真实设计数据。角色以 Agent A–D 匿名标识,时间显示为相对时间。真实系统仅在本地读取既有日志;此展示站没有日志接入口,也不连接你的机器。Every event, task and image on this site comes from fixed-seed simulated data, with no real design data. Roles use anonymous Agent A–D identifiers and relative time. The real system only reads existing logs locally. This showcase has no log ingestion endpoint and does not connect to your machine.
Agent A 指挥 · Agent B 执行 · Agent C 分析 · Agent D 审查Agent A Orchestrator · Agent B Executor · Agent C Analysis · Agent D Reviewer
 Neural Atlas